ROV & AUV Proximity Switches for Underwater Tooling
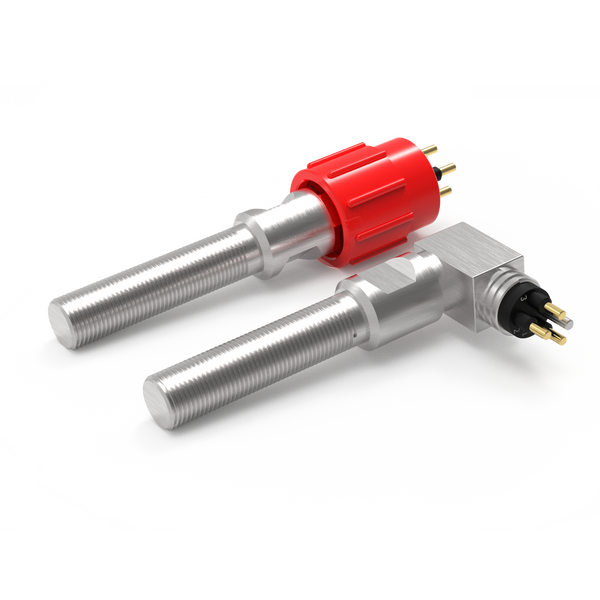
Compact underwater position feedback for ROV grippers, tool latches, docking mechanisms and deployed equipment, with integrated subsea cabling.
Underwater vehicles and intervention tools need local feedback from moving mechanisms. A discrete proximity switch can identify a defined gripper position, tool-latch state or docking target without requiring a full travel measurement.
The sensing assembly has to fit the vehicle as well as the electrical interface. Tool clearance, service access, target alignment and the first cable bend can constrain the design more than the nominal sensor dimensions.
Choose the feedback your equipment needs.
For rovs, auvs & underwater tooling, start with the task below. These routes narrow the product search; the final configuration is reviewed against your installation and operating conditions.
Confirm a defined position
Review non-contact proximity switching for an open, closed, home or engaged indication.
Resolve together: Target geometry, sensing gap, mounting and required contact state.
Compare proximity switches ↗Detect physical actuation
Where a cam or moving feature can press a plunger, review a mechanical limit switch as another sensing method.
Resolve together: Operating force, travel, overtravel and a separate mechanical stop.
Explore mechanical limit switches ↗Connect the sensing point
Define the lead between the sensor and equipment interface, including any movement and maintenance access.
Resolve together: Mating parts, pin allocation, cable length, routing and end termination.
Explore cable assemblies ↗Where each component fits.
Detect the defined mechanical position.
Review available mounting space, target material and approach direction. Confirm detection across the expected tool alignment tolerances.
- Grippers and tooling
- Tool change and latching
- Vehicle docking
Make the service interface practical.
Match the vehicle interface by verified reference and drawing. Physical resemblance does not establish connector compatibility.
- Exact mating reference and pin allocation
- Connection and disconnection conditions
- Access for inspection and replacement
Protect the route back to control.
Keep the harness clear of manipulator sweeps and tool changes. Provide strain relief and enough access to release the connection without pulling on conductors.
- Installed route and required length
- Fixed or moving duty
- Materials, restraints and termination details
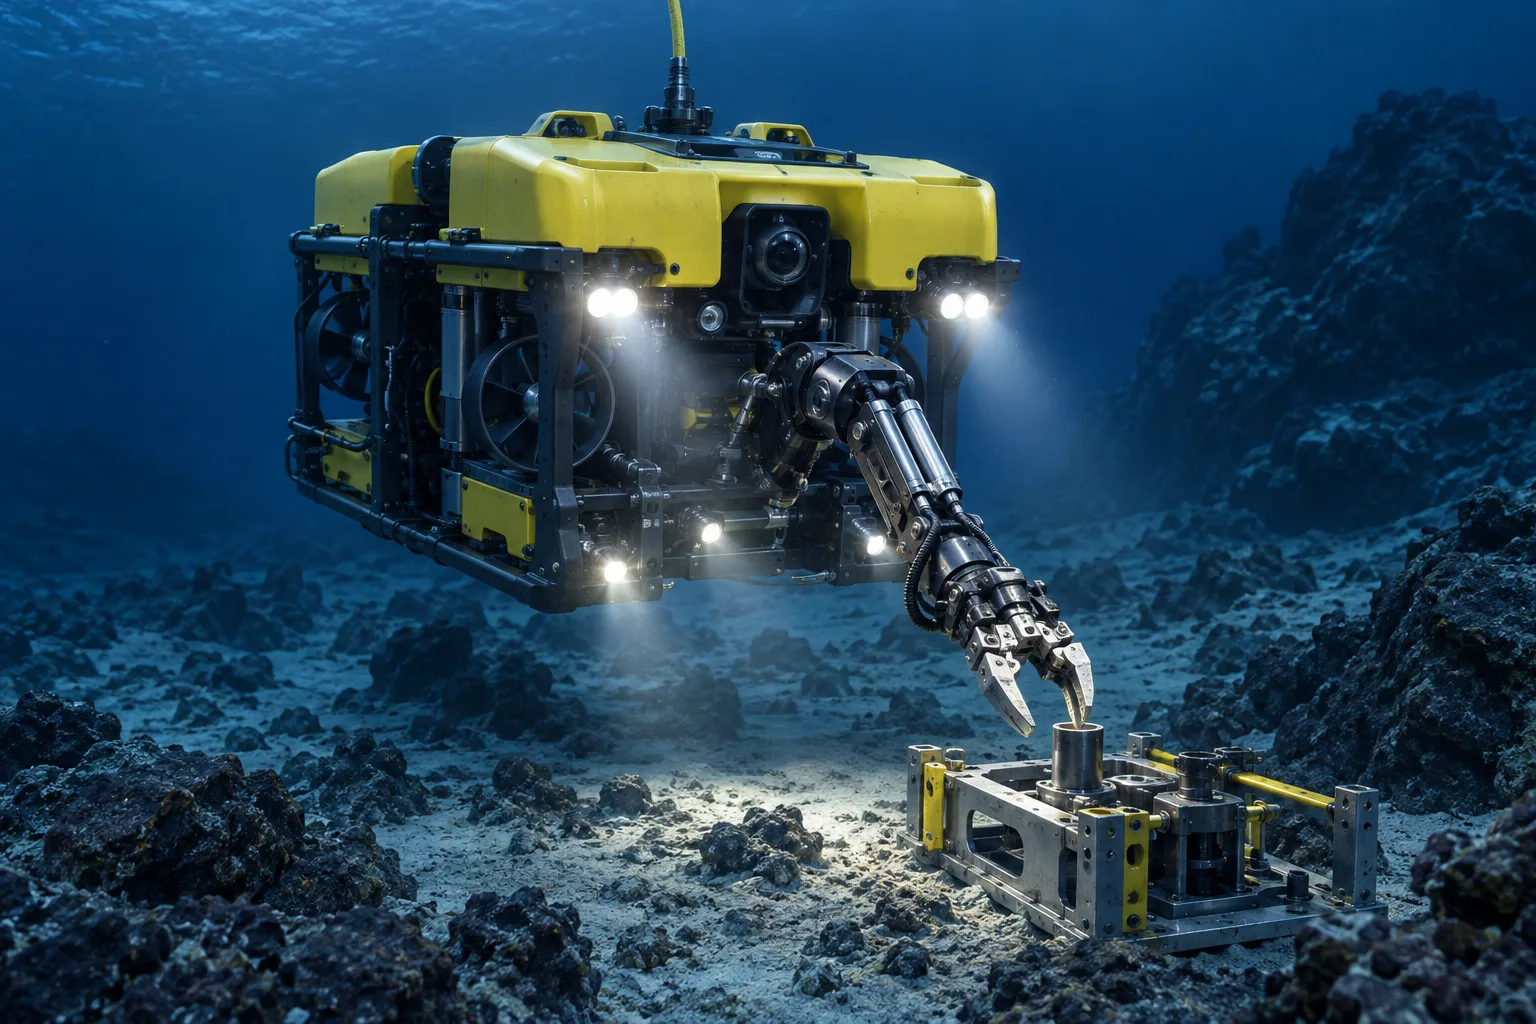
A tool latch on a retrievable ROV module
A stationary sensor can observe the latch target while a short harness connects the module to the vehicle. The interface brief should identify whether the tool is exchanged on deck or underwater, the mating connector and the control input state for latch engagement.
Contact us ↗From the equipment to the input.
A typical functional path. The final arrangement depends on the equipment and project specification.
- 01
Moving equipment
Detect a defined open, closed or home position on a moving tool.
- 02
Target & switch
The target reaches the defined detection point.
- 03
Cable assembly
A specified connection carries the switch state.
- 04
Control input
The equipment controller interprets the agreed contact logic.
The details to resolve together.
A closed gripper does not prove grip force
Position feedback reports a switching point; holding force or retained load requires separate assessment.
Define vehicle electrical inputs
Confirm voltage, permitted load, contact logic and diagnostic requirements before selecting the switch.
Review the complete operating depth
Use the pressure rating agreed for the assembled switch, connector and cable termination.
Bring the installation into the brief.
Share what you have. A drawing, an existing part reference or a description of the operating requirement is a useful starting point.
Contact us ↗- Equipment drawing and required switching positions
- Maximum immersion pressure, duration, temperature and media
- Target geometry, mounting space and electrical input
- Cable route, mating connector and maintenance method
Application examples describe potential arrangements, not installed DepthLink case studies. Final suitability, ratings and test requirements are agreed for the selected assembly.
What needs to be confirmed?
Grippers and tooling
Detect a defined open, closed or home position on a moving tool.
Tool change and latching
Monitor a latch or locking member at an agreed engagement point.
Vehicle docking
Detect a local docking target or capture-mechanism position; navigation remains a separate function.
Before you specify.
Does this replace an ROV navigation system?
No. These switches detect local mechanical positions on the vehicle or tool. They do not determine the vehicle’s geographic position.
Can the switch connect to an existing vehicle harness?
Potentially. Supply the exact mating connector, pin allocation and input requirements so the assembly interface can be reviewed.
See the complete connection.
Explore how DepthLink position switches, underwater cable assemblies and custom equipment interfaces work together. Contact our team to discuss your installation.
Explore system engineering ↗